NIDAR: Autonomous Multi-Drone Search & Aid Delivery
Pixhawk, ArduPilot, PX4, QGroundControl, Moon Lab
A team of autonomous drones that searches a 10-hectare flood zone, geotags up to 10 survivors and drops a 200 g aid kit near each one, with no external network and a 25 kg limit on all drones combined. I build and integrate the airframes and set up the flight controllers, including calibration, parameters and failsafes (return-to-launch, low battery, geofence, kill switch).
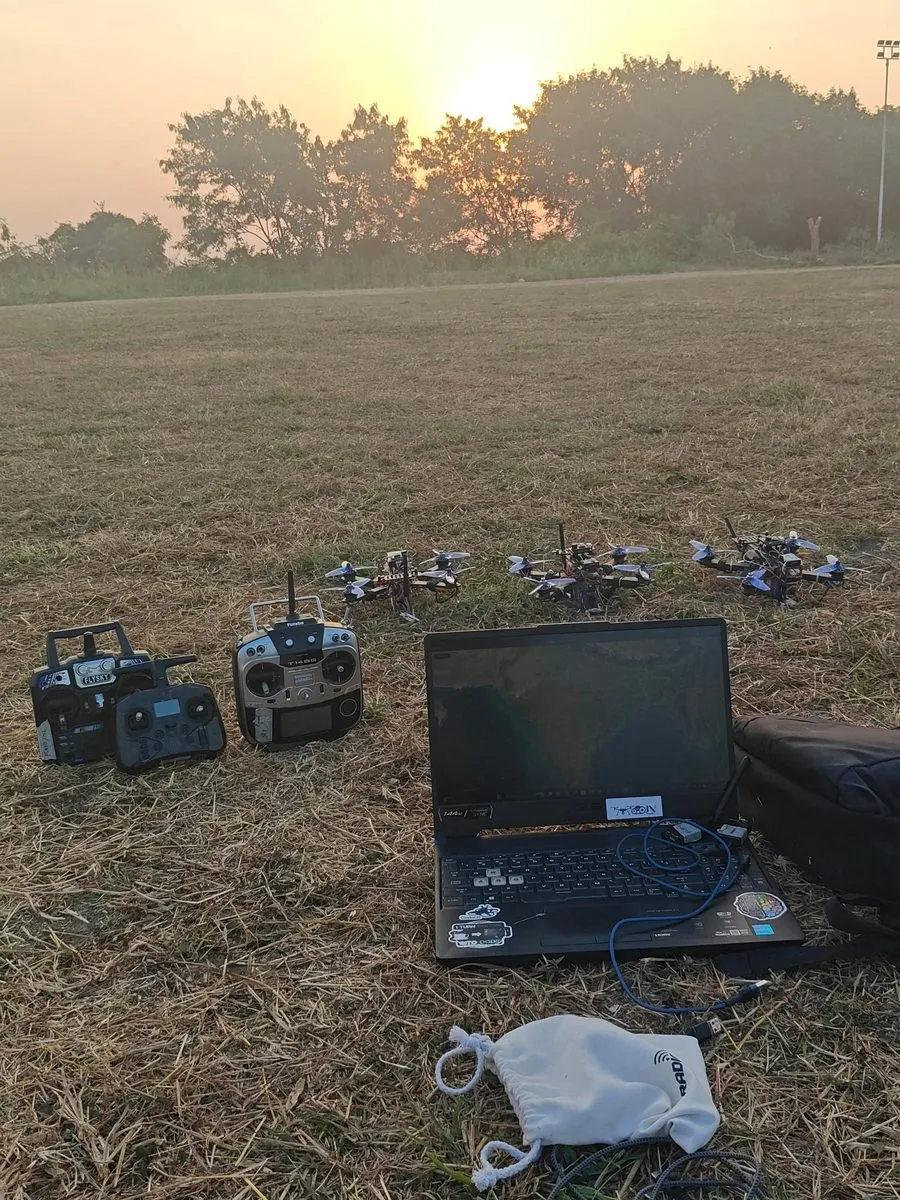
Field test setup: three drones, RC transmitters and the ground control station running QGroundControl.